|
GCVL
Multi-platform (Windows, Unix and Mac OS) C++/OpenCL/CUDA library with several Computer Vision algorithms.
|
|
GCVL
Multi-platform (Windows, Unix and Mac OS) C++/OpenCL/CUDA library with several Computer Vision algorithms.
|
#include <oclblockmatching.h>
Public Member Functions | |
| BlockMatching (Core &core, std::string inputLeft, std::string inputRight, std::unique_ptr< unsigned char[]> &output) | |
| ~BlockMatching () | |
| void | setAggDim (const int val) |
| Sets the aggregation window dimension. | |
| void | setMaxDisp (const int val) |
| Sets the maximum disparity. | |
| void | setNormalize (const bool val) |
| Activates or deactivates disparity map normalization. | |
| unsigned int | getWidth () |
| Obtains image width. | |
| unsigned int | getHeight () |
| Obtains image height. | |
| void | prepare () |
| Function that performs pre-processing steps. | |
| void | setArgs () |
| Function that sets the kernel arguments. | |
| void | launch () |
| Launch the algorithm. | |
| void | postpare () |
| Function that performs post-processing steps. | |
| gcvl::opencl::BlockMatching::BlockMatching | ( | Core & | core, |
| std::string | inputLeft, | ||
| std::string | inputRight, | ||
| std::unique_ptr< unsigned char[]> & | output | ||
| ) |
| unsigned int gcvl::opencl::BlockMatching::getHeight | ( | ) | [inline] |
Obtains image height.
| unsigned int gcvl::opencl::BlockMatching::getWidth | ( | ) | [inline] |
Obtains image width.
| void gcvl::opencl::BlockMatching::launch | ( | ) | [virtual] |
Launch the algorithm.
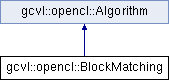
Implements gcvl::opencl::Algorithm.
| void gcvl::opencl::BlockMatching::postpare | ( | ) | [virtual] |
Function that performs post-processing steps.
Implements gcvl::opencl::Algorithm.
| void gcvl::opencl::BlockMatching::prepare | ( | ) | [virtual] |
Function that performs pre-processing steps.
Implements gcvl::opencl::Algorithm.
| void gcvl::opencl::BlockMatching::setAggDim | ( | const int | val | ) | [inline] |
Sets the aggregation window dimension.
| val | aggregation window dimension in pixels. |
| void gcvl::opencl::BlockMatching::setArgs | ( | ) | [virtual] |
Function that sets the kernel arguments.
Implements gcvl::opencl::Algorithm.
| void gcvl::opencl::BlockMatching::setMaxDisp | ( | const int | val | ) | [inline] |
Sets the maximum disparity.
| val | maximum disparity in pixels. |
| void gcvl::opencl::BlockMatching::setNormalize | ( | const bool | val | ) | [inline] |
Activates or deactivates disparity map normalization.
| val | normalization usage. |
 1.7.6.1

